AGV Machine Control
An automated guided vehicle that picks up a box, identifies its color, delivers red boxes to one side and green to the other, and returns to its starting point. My role: Control Logic Engineer.
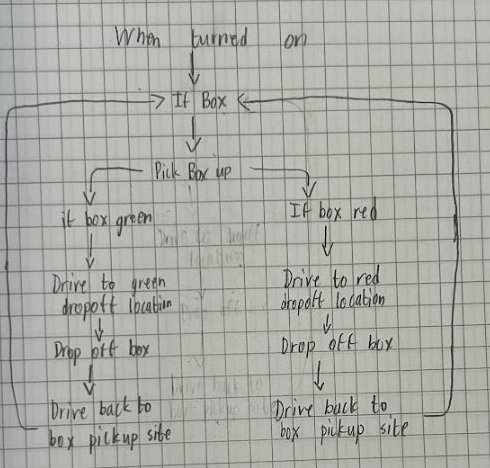
Control logic
when turned on:
  loop:
    if box detected:
      pick up box
      if red:   drive to right drop-off
      if green: drive to left drop-off
      drop off box
      drive back to pickup site
I wrote the pseudocode and the program logic: sensing, the color branch, and the return path. The box had to be lifted, not dragged.
Process
- Research: I studied five reference mechanisms (VEX pulley lift, delivery robots, warehouse robots, Roomba, pincer gripper) and how sensors control each one.
- Selection: each of us sketched designs, and we chose one with a points vote.
- Build: we split up the subsystems, combined them, redesigned several times, then programmed and tested repeatedly.
Limitations and next steps
- Travel distances were hard-coded. Next time: sensor-driven movement that decides how far to drive and turn based on its surroundings.
- A separate motor for each wheel for finer control; drop the redundant second lift motor.
- Teamwork: assign each person a subsystem early, and collect ideas in a shared doc before discussing them.